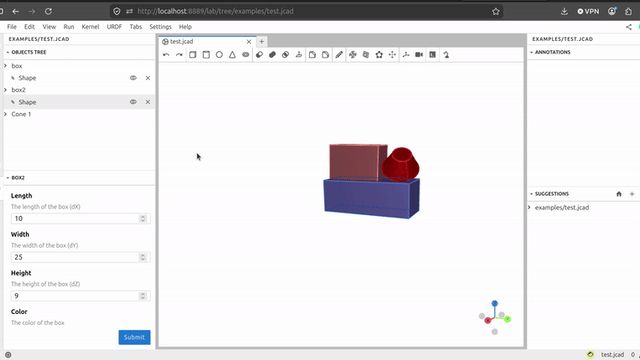
A Robotics Workbench for JupyterCAD
A unified in-browser workflow from CAD to URDF kinematics
A unified in-browser workflow from CAD to URDF kinematics
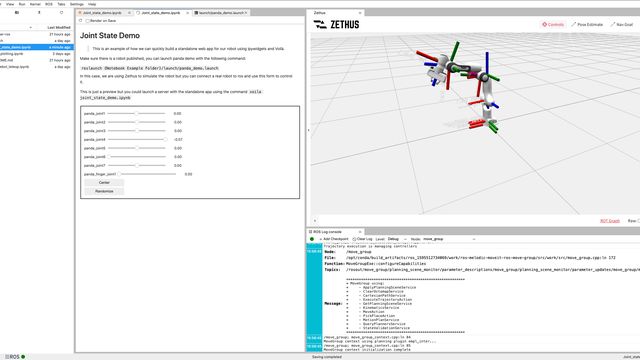
Building a cloud robotics development platform using JupyterLab and ROS
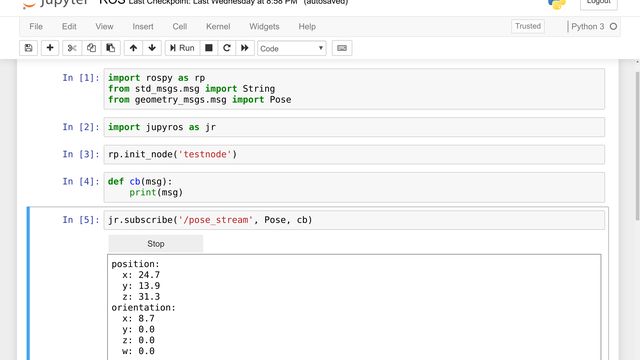
Project Jupyter is a huge hit in data science, but it has not yet found widespread adoption in robotics. Today, we are releasing the first version...